Hello my name is

George Partridge

I'm a second-year Mechanical Engineering student at Georgia Tech. I'm most interested in robotics and rapid prototyping. If you're working on either, get in touch.

Updated October 2026

Building a four-wheel differential swerve robot. When I have time, I go back to the speed drone and work on GPS autonomy.

Projects

SolidWorks render of the speed drone
Personal Project CFD 325 km/h GPS peak

Quadcopter Speed Drone

A 3D-printed quadcopter built from stock 5" parts to go as fast as possible. It carries GPS so I can add autonomous flight later. I designed the airframe in SolidWorks around the electronics and camera, then compared four fuselage shapes in OpenFOAM at angles from −4° to 13° and speeds from 10 to 100 m/s. I soldered all the electronics myself and tuned it in ArduPilot.

  • 325 km/h GPS peak on the third flight, unverified (172 km/h on the maiden, at 48% throttle)
  • 880 g printed in PLA
  • Peak L/D of 9.1 at 5°, and passively pitch-stable
CAD model of the four-wheel swerve robot with orange LiDAR on top
In Progress Fusion 360 FEA ESP32 KiCad

4-Wheel Differential Swerve Robot

Each of the four wheels steers and drives on its own, so the robot can move in any direction while it turns. The chassis is fully 3D printed and carries custom electronics and a LiDAR for mapping.

Light building

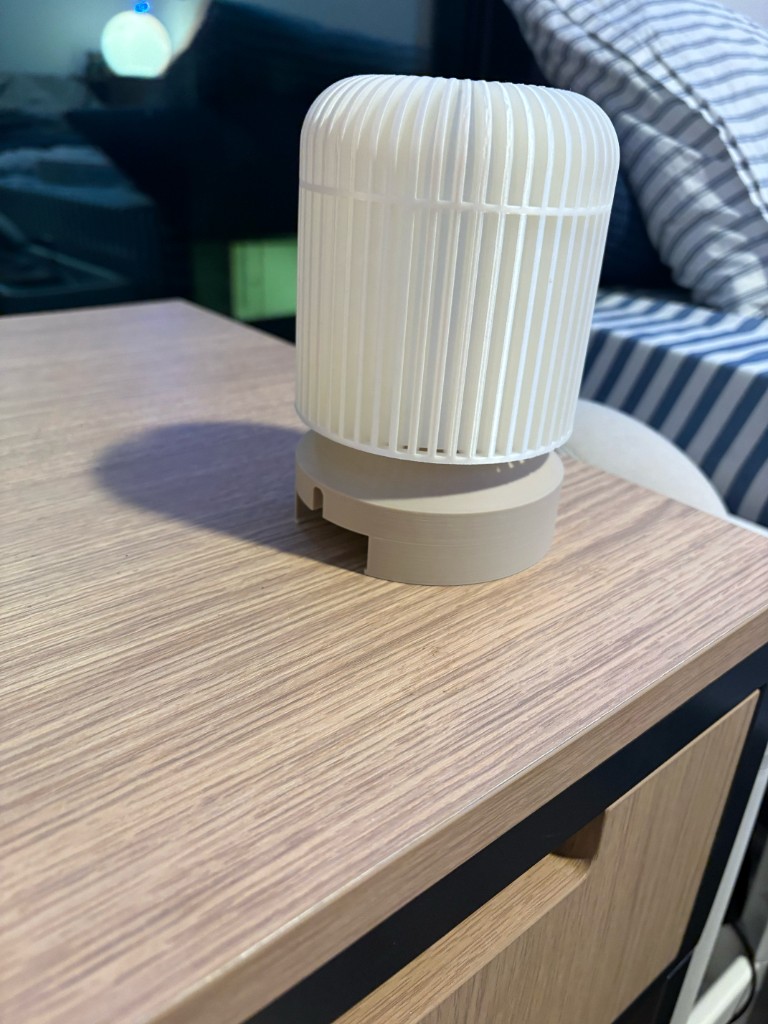
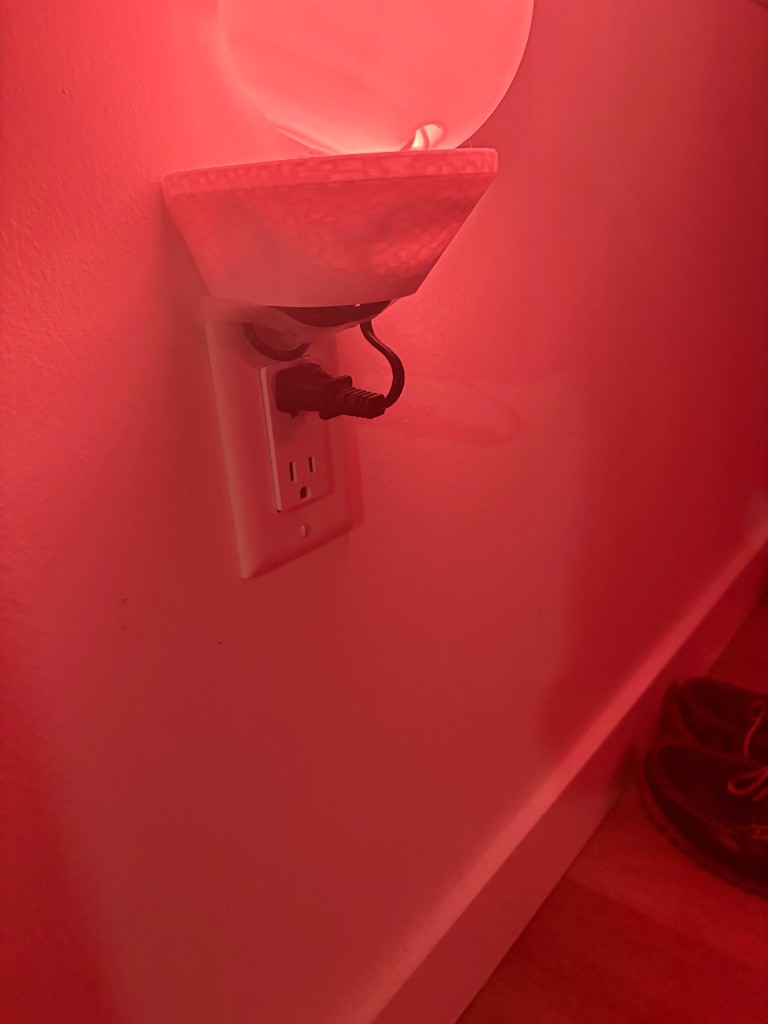
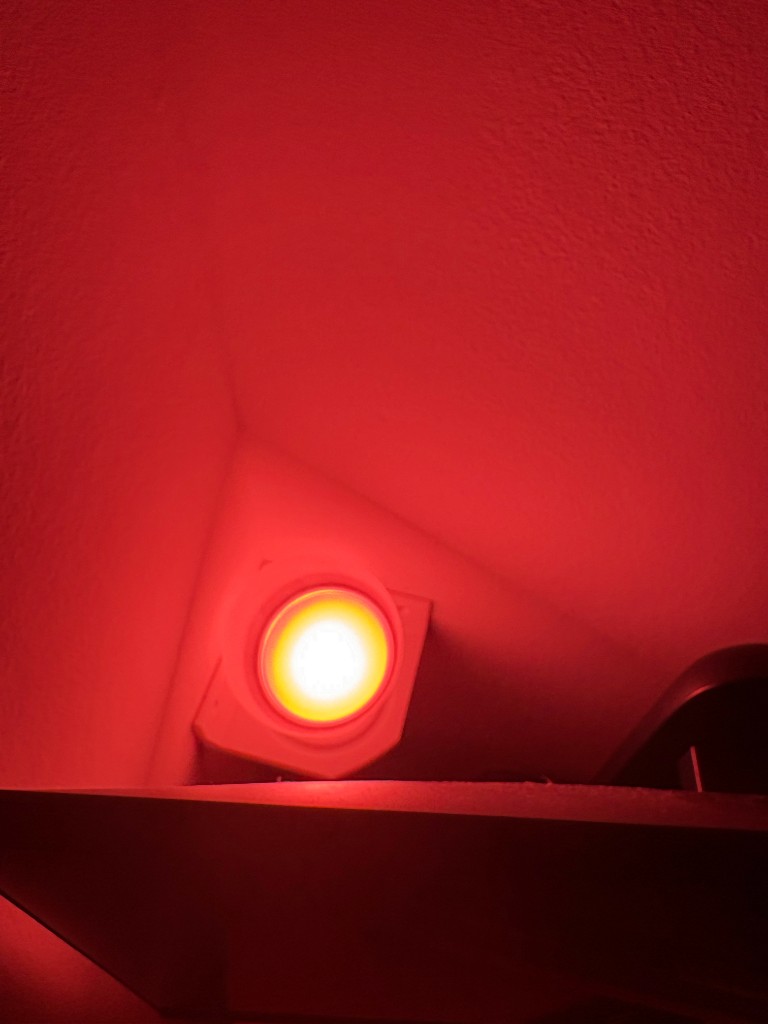
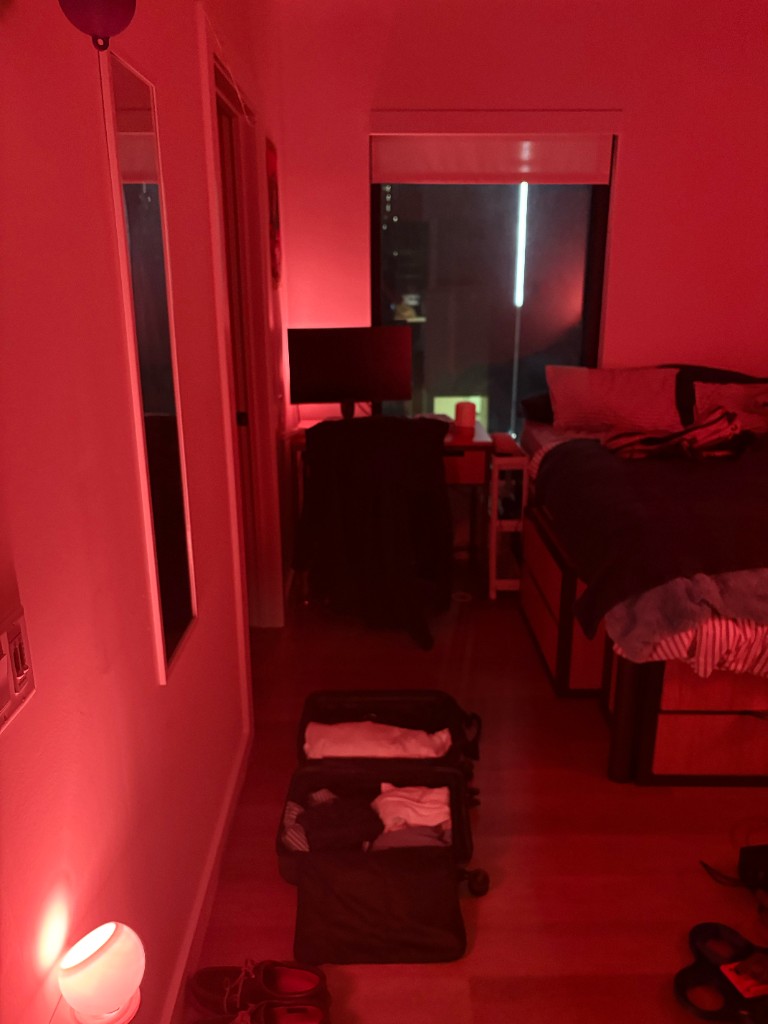
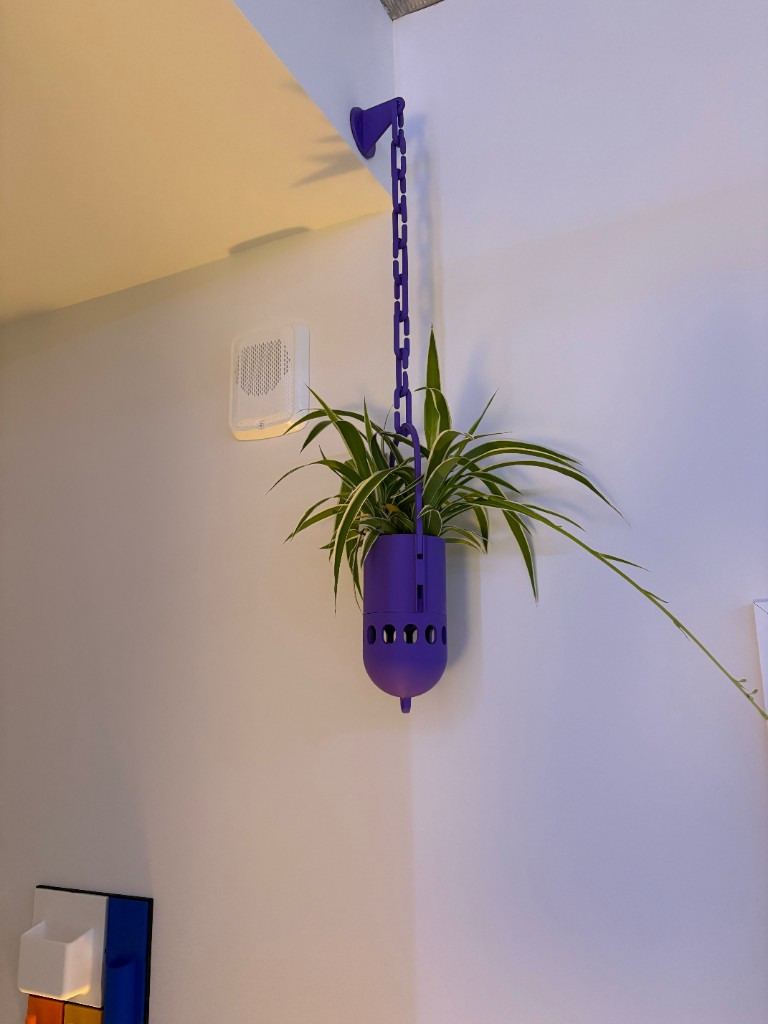
Lamps and fixtures I print on my Bambu A1 between bigger projects, plus a hanging planter. I modelled the mini lamp in Fusion as three parts you can download below, a base, a clicker and a shade.

Fusion render of the mini lamp, three-quarter view
Mini lamp
Printed mini lamp on a bedside table
Printed, awaiting bulb
Printed orb night light plugged into a wall outlet
Orb
Printed fixture with a round LED, lighting a wall red
Custom fixture
Bedroom lit red by the orb
Orb, lighting the room
Purple printed hanging planter with a spider plant
Hanging planter